Hi, I'm Lukas
I'm Lukas Deschryver, a developer from Belgium. I like to code, and I especially like building things people actually use.
Most of my time goes into free, open-source tools for Euro Truck Simulator 2 and American Truck Simulator, including MonoCruise. I share my work on my YouTube channel.
Everything I release is free, open source and tracking-free. That's the whole deal.
Get in touch
How it all started
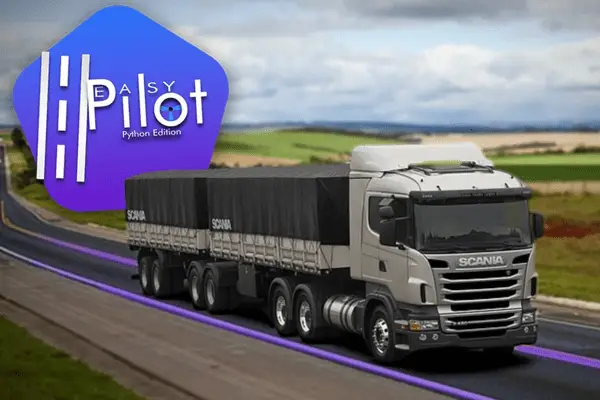
I started coding Python in school in 2022, and I quickly fell in love with the language. I had already been driving in ETS2 and TruckersMP at that point, and wanted to experiment with taking screenshots of the game and giving the game a steering command. This was EasyPilot, the first project I ever made.
During the making of EasyPilot, I took some breaks and drove a lot on the famous CD road. I was getting tired of constantly having to switch between pedals in these busy areas because of the constant braking. That made me work on a small formula using some of the EasyPilot code, and I wrote onepedaldriveETS2.py. It wasn't much, but it was a solid starting point for MonoCruise.
After I noticed ETS2LA was getting popular and better than EasyPilot, I stopped working on EasyPilot and started a new project: MonoCruise. At first it was really just a UI for the onepedaldriveETS2.py formula plus a settings menu. I already had the idea of building my own cruise control system, hence the name Mono (one-pedal drive) Cruise (cruise control), but that plan didn't come together until a couple of months later, once I'd taken the time to make it actually feel right to use.
After spending some more time on the CD road, I got annoyed by having to constantly disable the cruise control because of traffic. After hearing from Tumppi, the creator of ETS2LA, that I could use ETS2LA's traffic plugin in MonoCruise, I immediately started working on a simple ACC for TruckersMP.
After making this ACC, I noticed I could directly use the leading vehicle's data for a simple AEB system that would brake when a collision was inevitable. It wasn't a reliable system, since it relied on the ACC's tracking, but it worked some of the time.
MonoCruise kept growing with every new feature, but two problems were holding it back. First, any single error in the code would crash the whole program, meaning no pedal output at all. Second, the UI had grown so much that Tkinter's CPU-based rendering just couldn't keep up anymore. Between those two, I decided it was time for a full rewrite.
Rewriting MonoCruise gave me a lot of room to go in-depth with the systems (in hindsight, this might be why it took over 6 months of dev time). I completely reworked the AEB to trigger for all kinds of danger, made MonoCruise run across multiple threads to prevent full crashes, and fully reworked the ACC/CC systems.
And that is where we are.
What next?
What a good question.
I plan to keep supporting and enhancing MonoCruise. Maybe not by adding many more features, but by drastically improving the UX.
For the near future, I plan to gather 2000+ seconds of valuable driving data with testers to train a neural network.
"Aw man, AI again..."
Not exactly. I want to improve the AEB's false positives and negatives so MonoCruise has a better understanding of danger and easier tracking for the ACC. Neural networks might sound like a big deal, but they don't have to be. In MonoCruise's case, it could even reduce processing time by replacing about 10 complicated per-vehicle filters with quick math instead.
As for the very far future, I want to do something more with the AEB system I've built, though what exactly is still unclear.
My projects:
-
Read more about MonoCruise ACC and AEB for ETS2
MonoCruise
Creates a smoother and safer driving experience for ETS2. Has features like AEB and ACC.
Read more about MonoCruise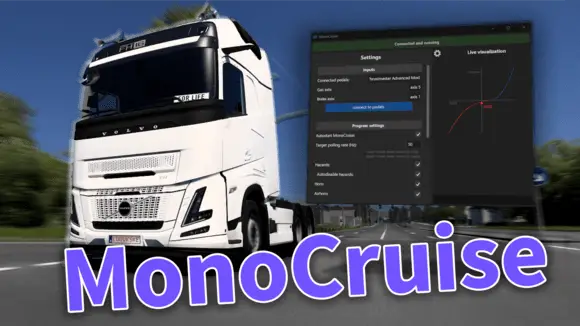
-
Read more about EasyPilot lane assist for ETS2
EasyPilot
A lane keeping assist to keep you in your lane in ETS2 (discontinued)
Read more about EasyPilot